Coming soon · CAD in progress
Robotic Arm: From Motion to Mechanism
A robotic arm I plan to control, starting with the hand. Currently working on CAD for a segmented index finger and exploring its joints and tendon routing.
- CAD in progress
- Mechanical design
- Robotics
Overview
The goal is to build a robotic arm that I can control. The current focus is the hand mechanism, starting with a three-segment index finger. This project is in the planning and CAD stage.
My Role
I am working on the CAD and mechanical layout, considering how the finger segments connect to each other and to the palm.
The idea
Turn a controllable robotic arm idea into a physical mechanism, beginning with one finger before developing the rest of the hand and arm.
Development Process
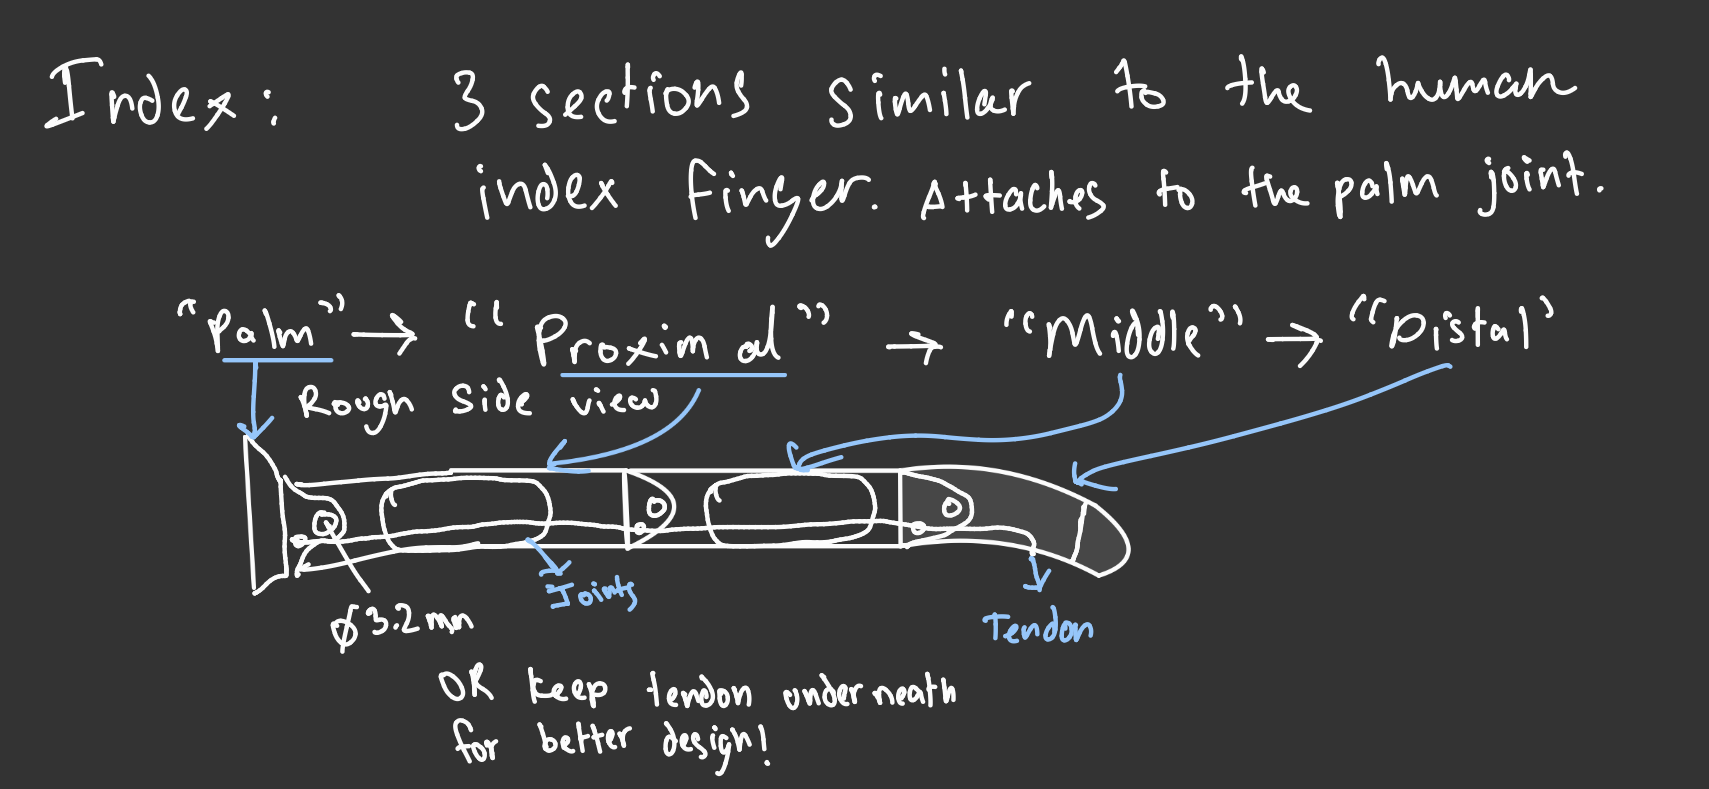
The concept divides the index finger into proximal, middle, and distal segments. I am exploring the pivot joints and a separate tendon path along the palm side to curl the finger.
Current progress
Current progress: concept sketch and CAD work. Fabrication, actuation, and control testing are still ahead.
What I am exploring
I am learning how joint geometry, clearances, and tendon routing affect a finger mechanism. The dimensions in the sketch are preliminary and still need to be checked through prototyping.
Technologies
- CAD
- Joint design
- Tendon routing